Projects (10)
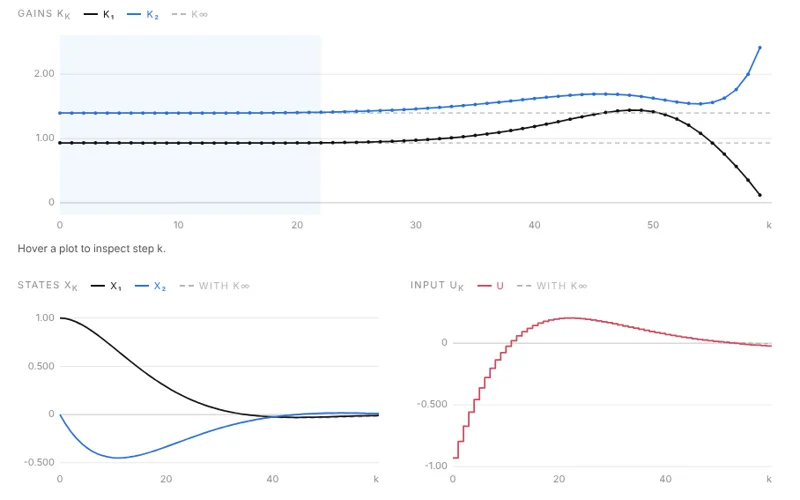
Backward Riccati recursion with a terminal cost: watch time-varying LQ gains converge to the infinite-horizon LQR gain as you tune N, Q, R and S.
View demo →
View demo →
View demo →
View demo →
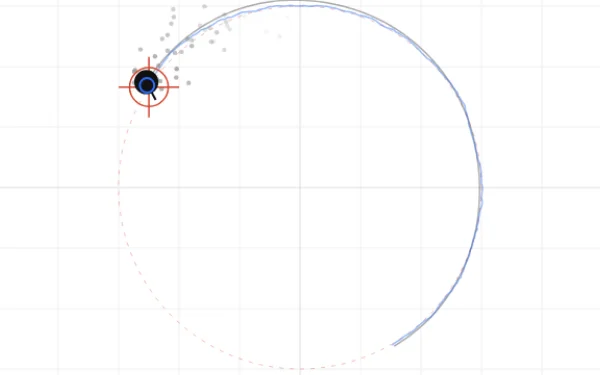
Steer a noisy 2D puck with LQR and a Kalman filter, with the Riccati equations (DARE/CARE) solved live in the browser.
View demo →
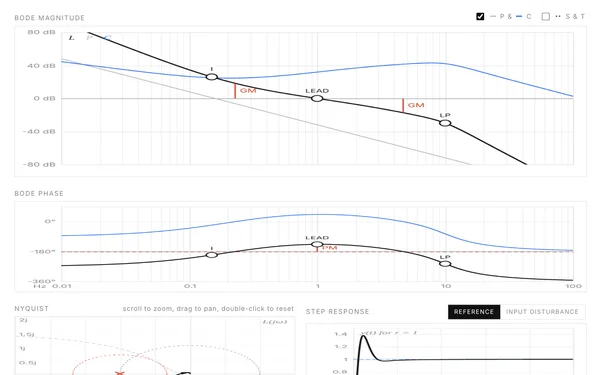
Shape a feedback loop by dragging lead, lag, integrator, low-pass and notch elements on a live Bode plot, with Nyquist, step response and margins.
View demo →
View demo →
View demo →
View demo →
View demo →